 PluraFusion
Photos to Twinin every paid edition
Photos in. A measured twin out.
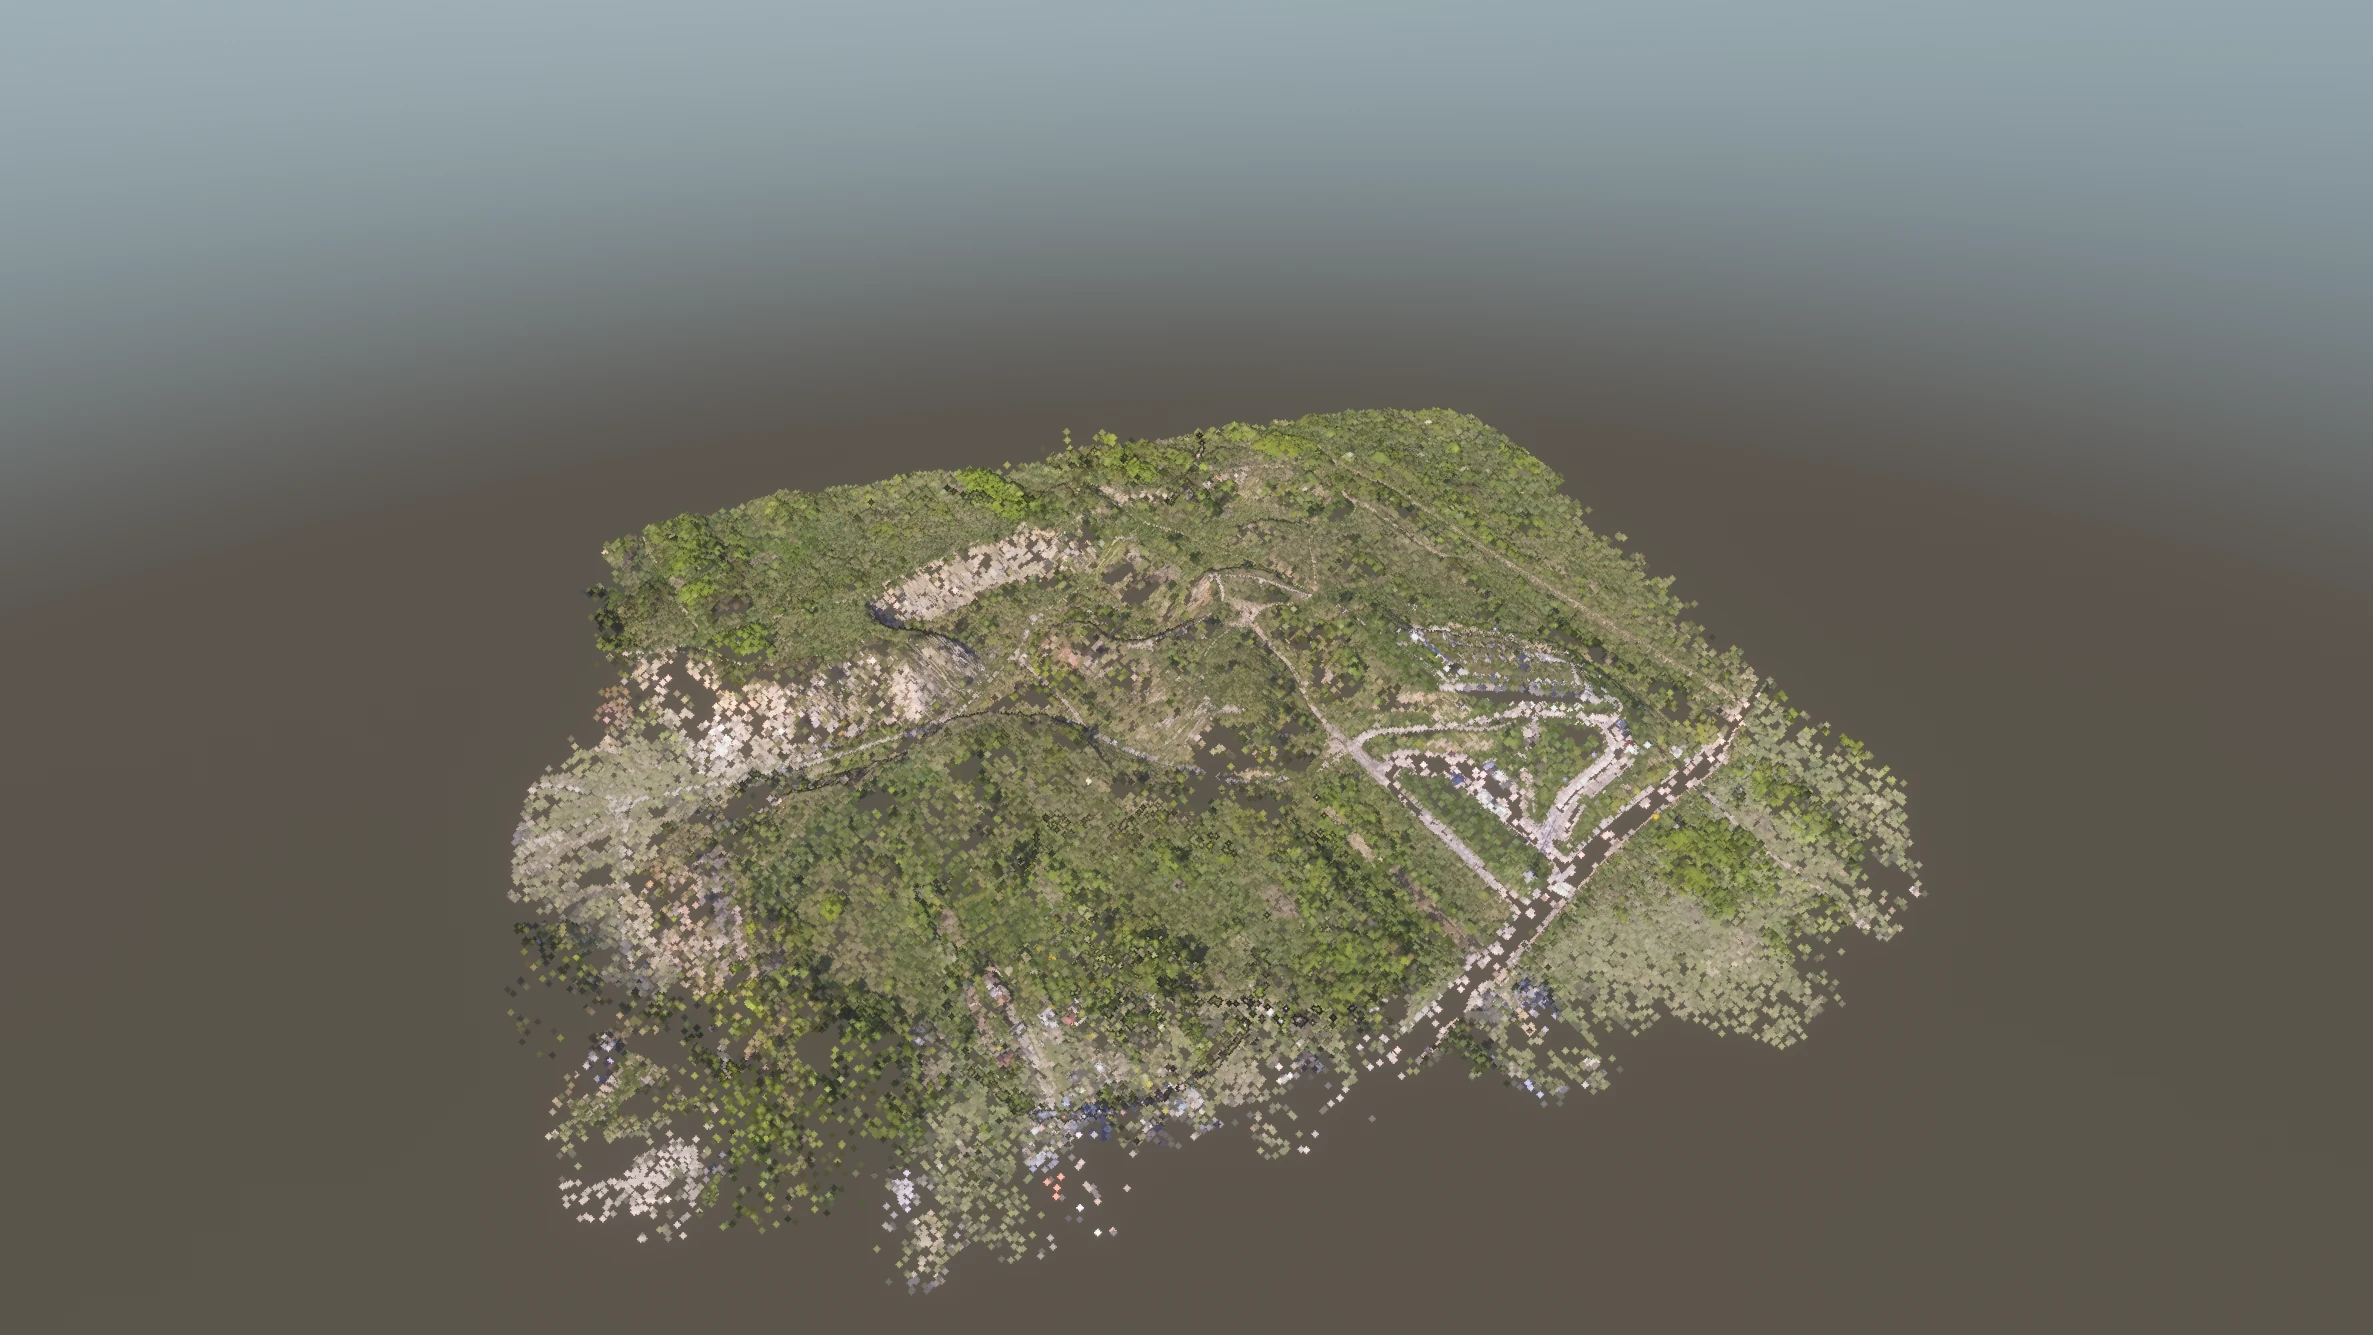
One drone flight, a folder of photographs, a laser scan or a video — to a dense cloud, a mesh and Gaussian splats, in a real coordinate system, on your own graphics card.
The rollwhat the drone saw
Every photographis a measurement.
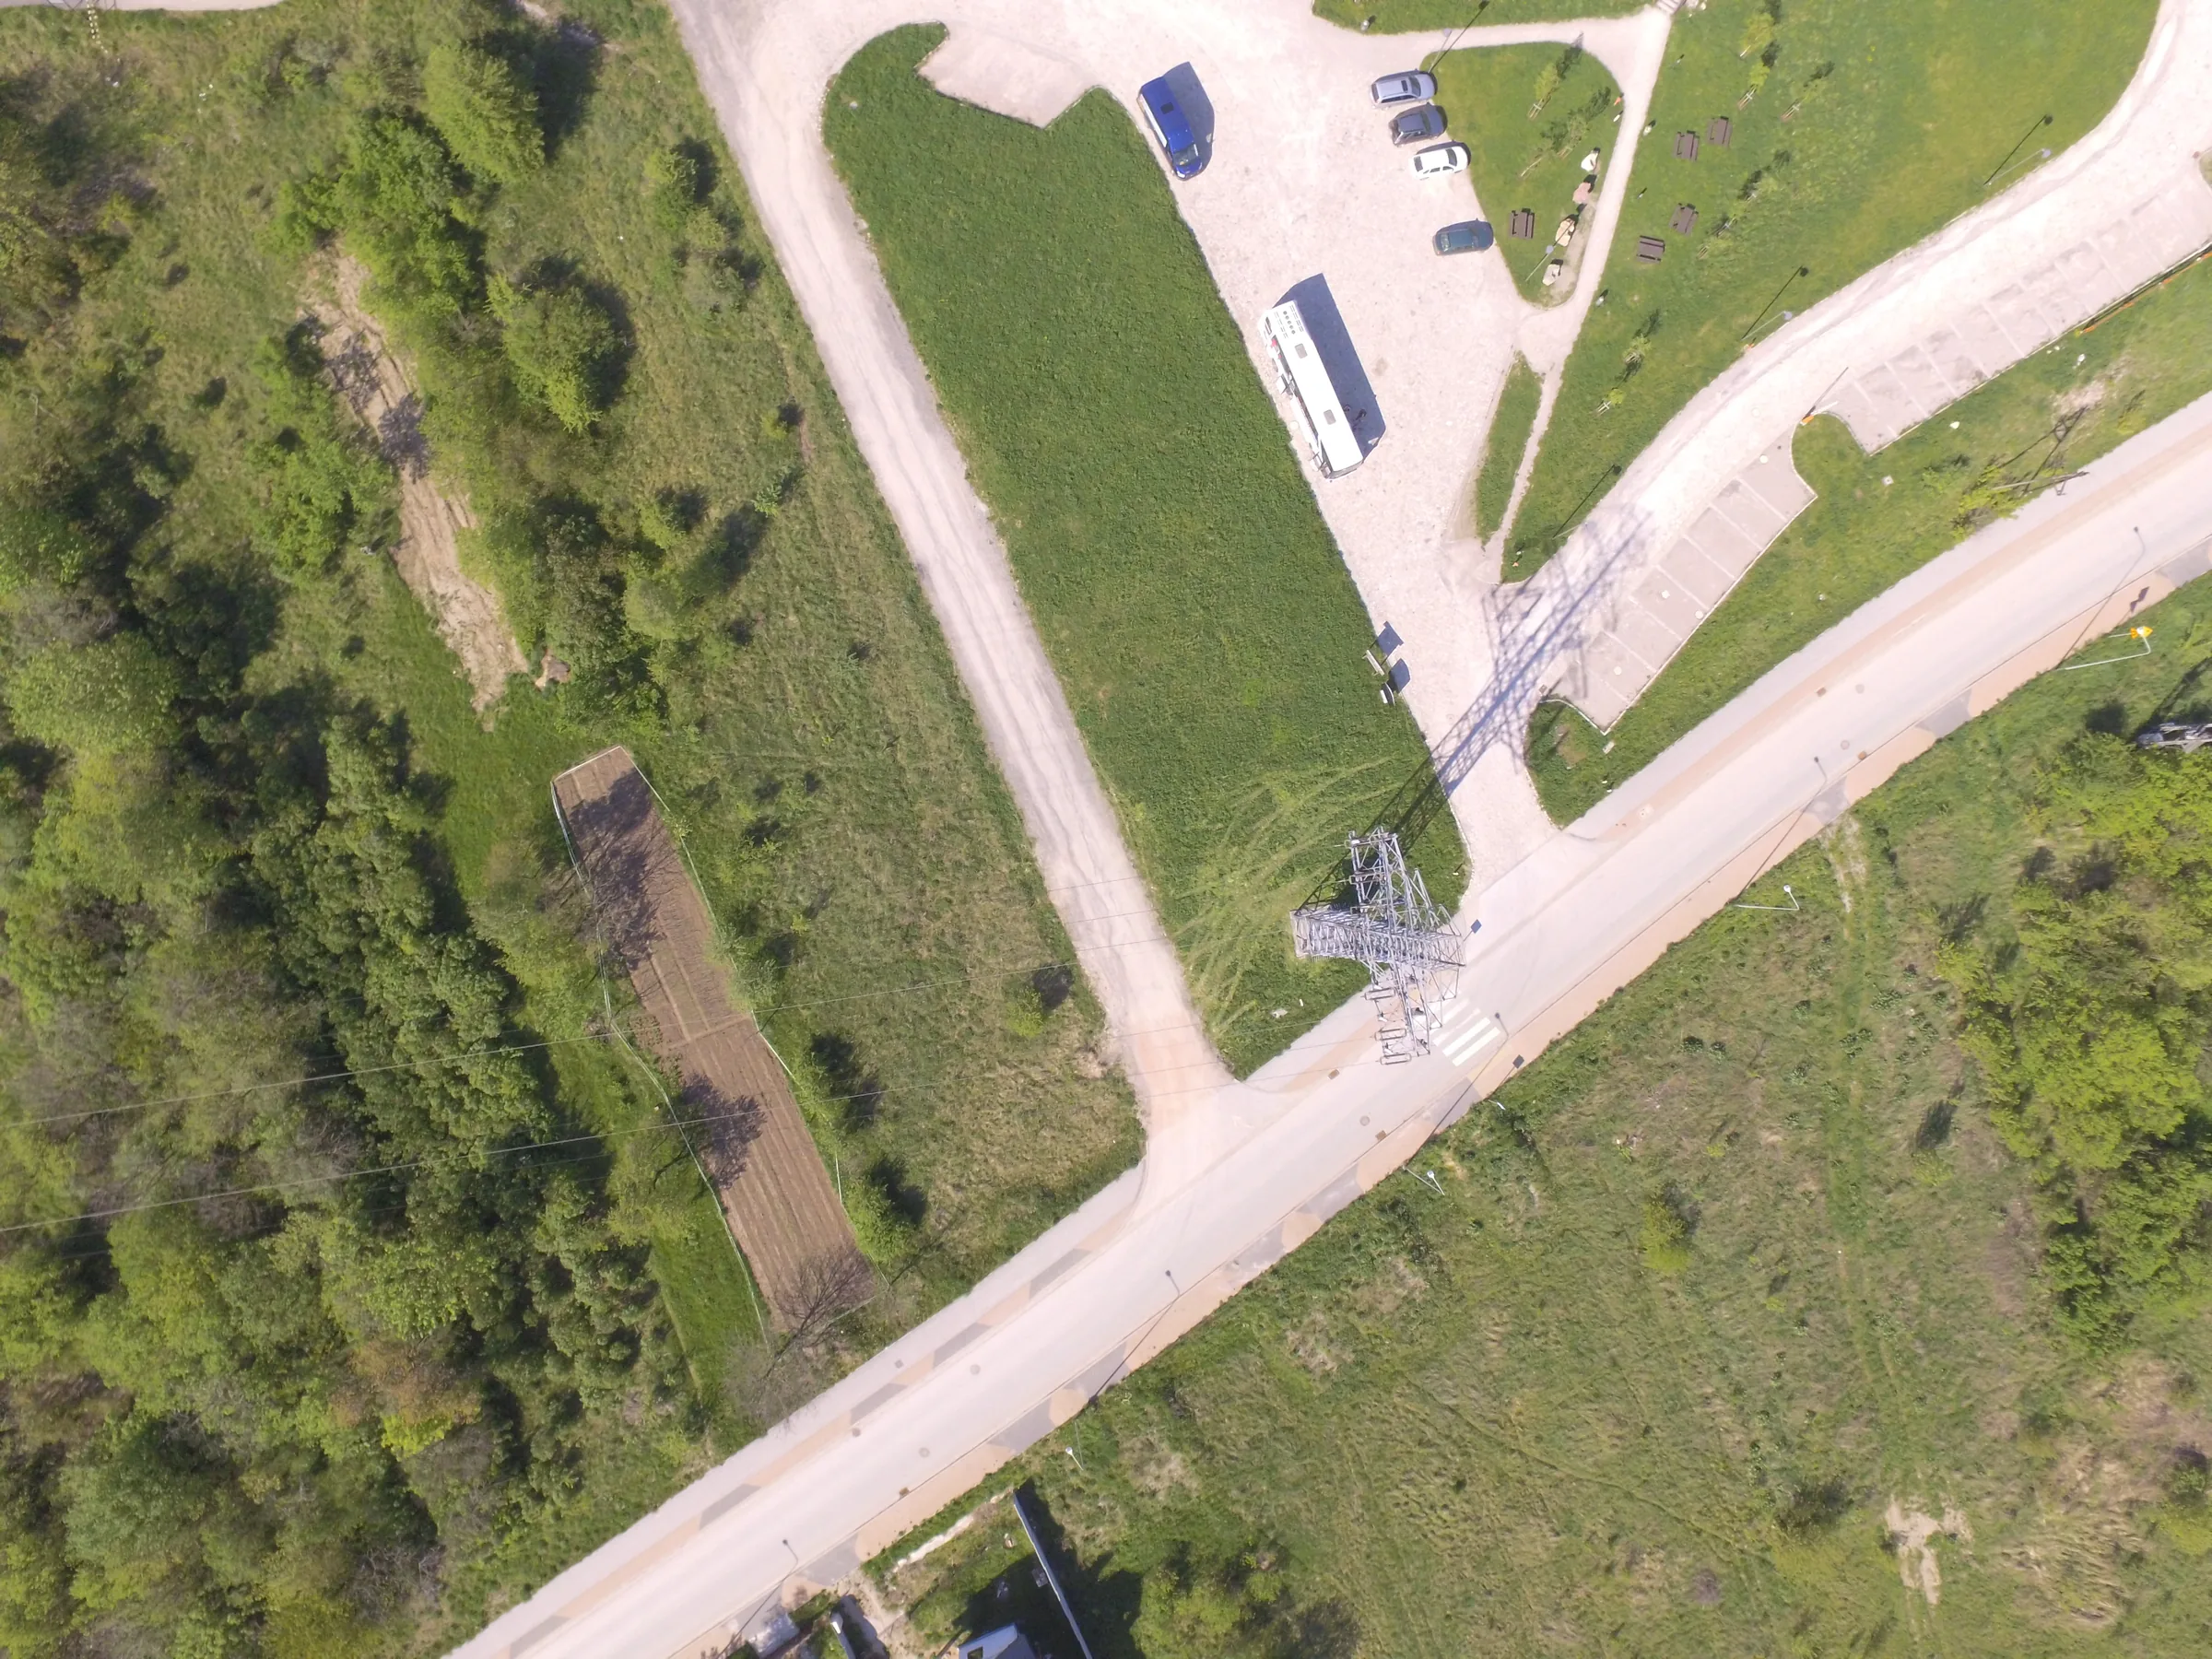
Each frame carries where it was taken and how. The application reads that, finds the same points across overlapping frames, and solves where every camera stood.
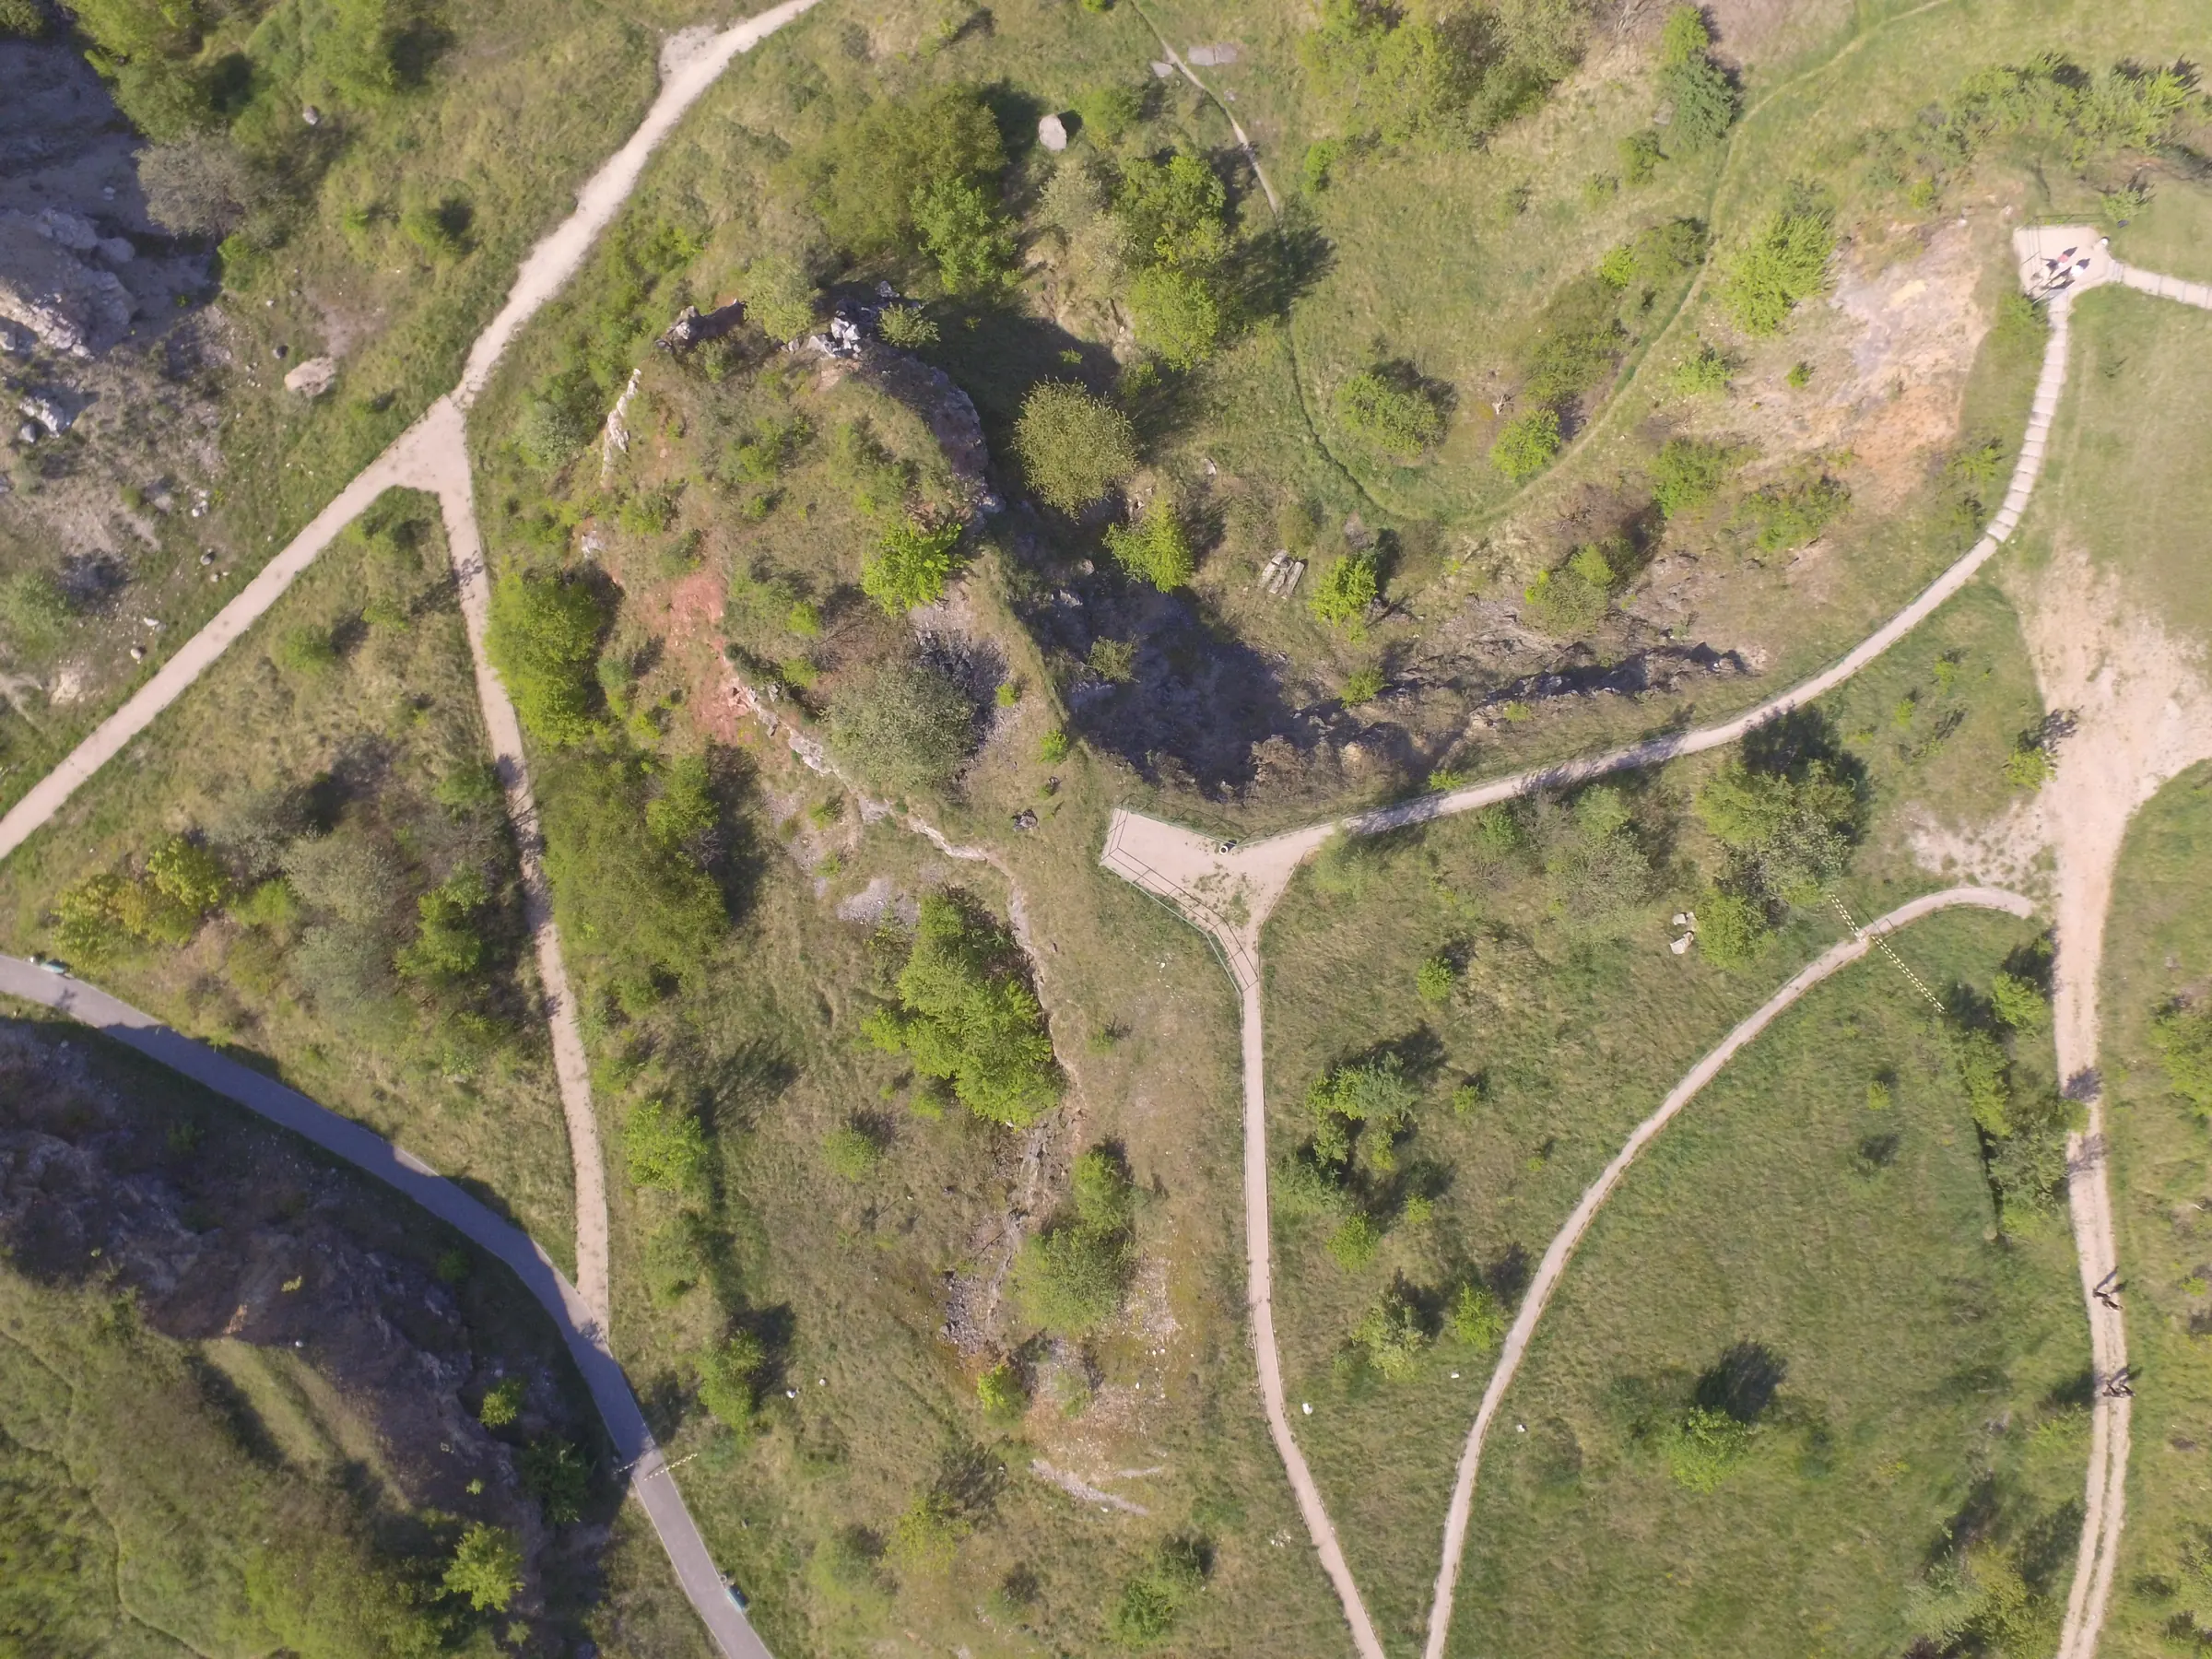
Consecutive frames of one flight, as they came off the camera · odm_wietrznia, © 2019 Tomasz Nycz, MIT
The stagesone solve, every resultstages 2–4 from one camera
From a photographto a twin.
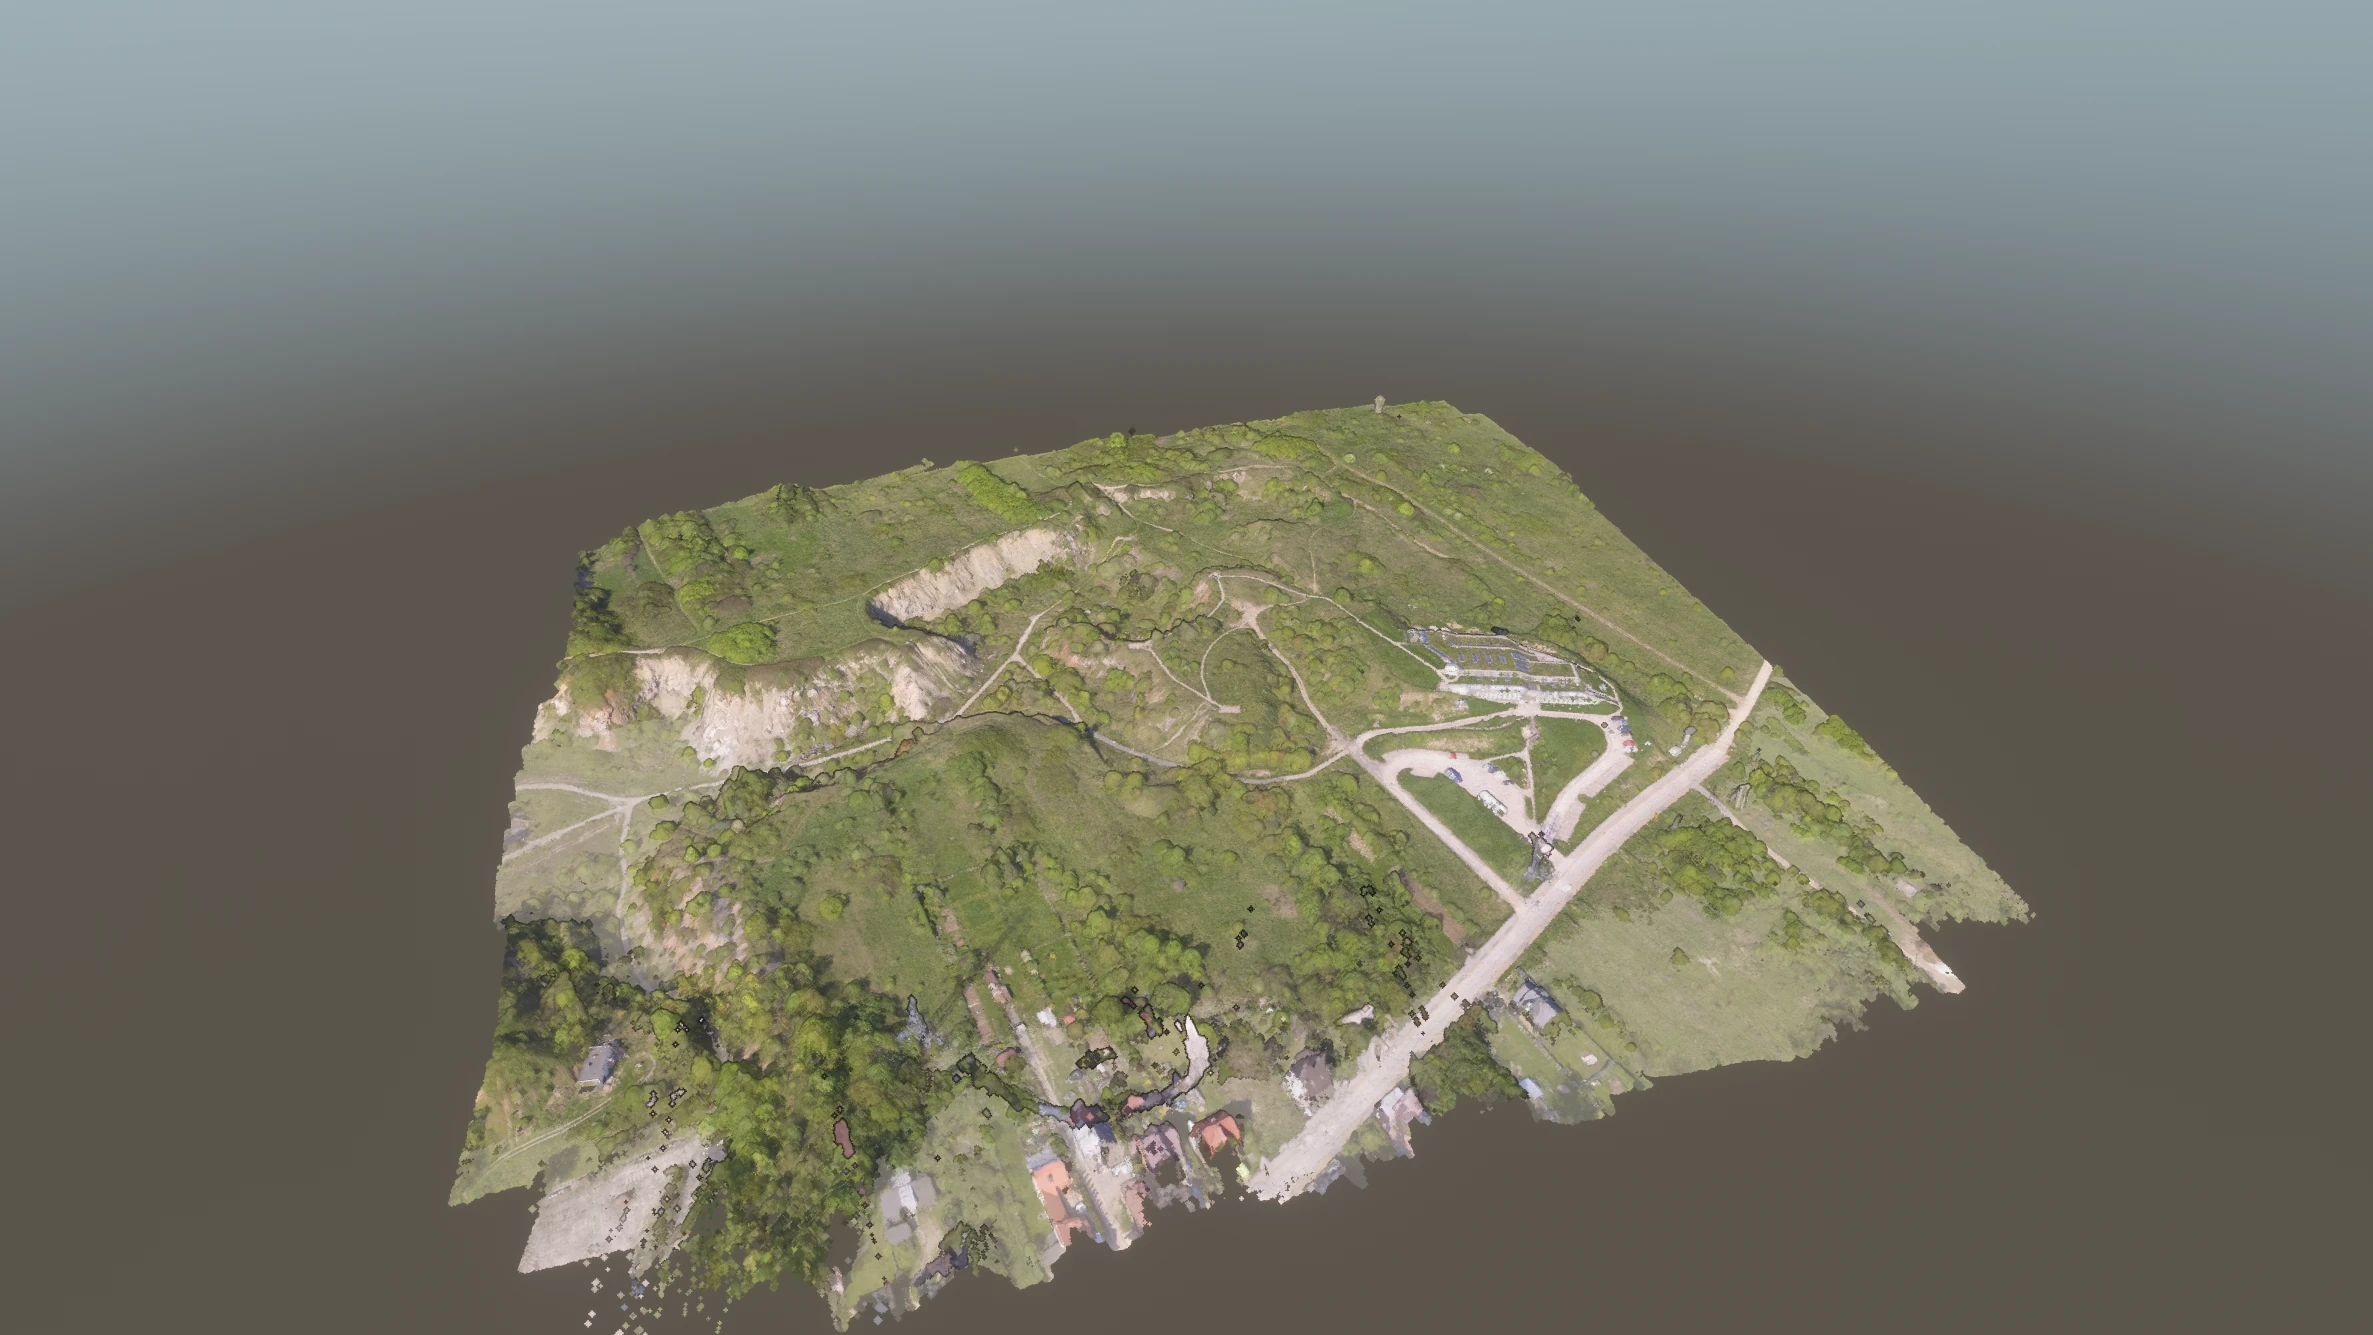
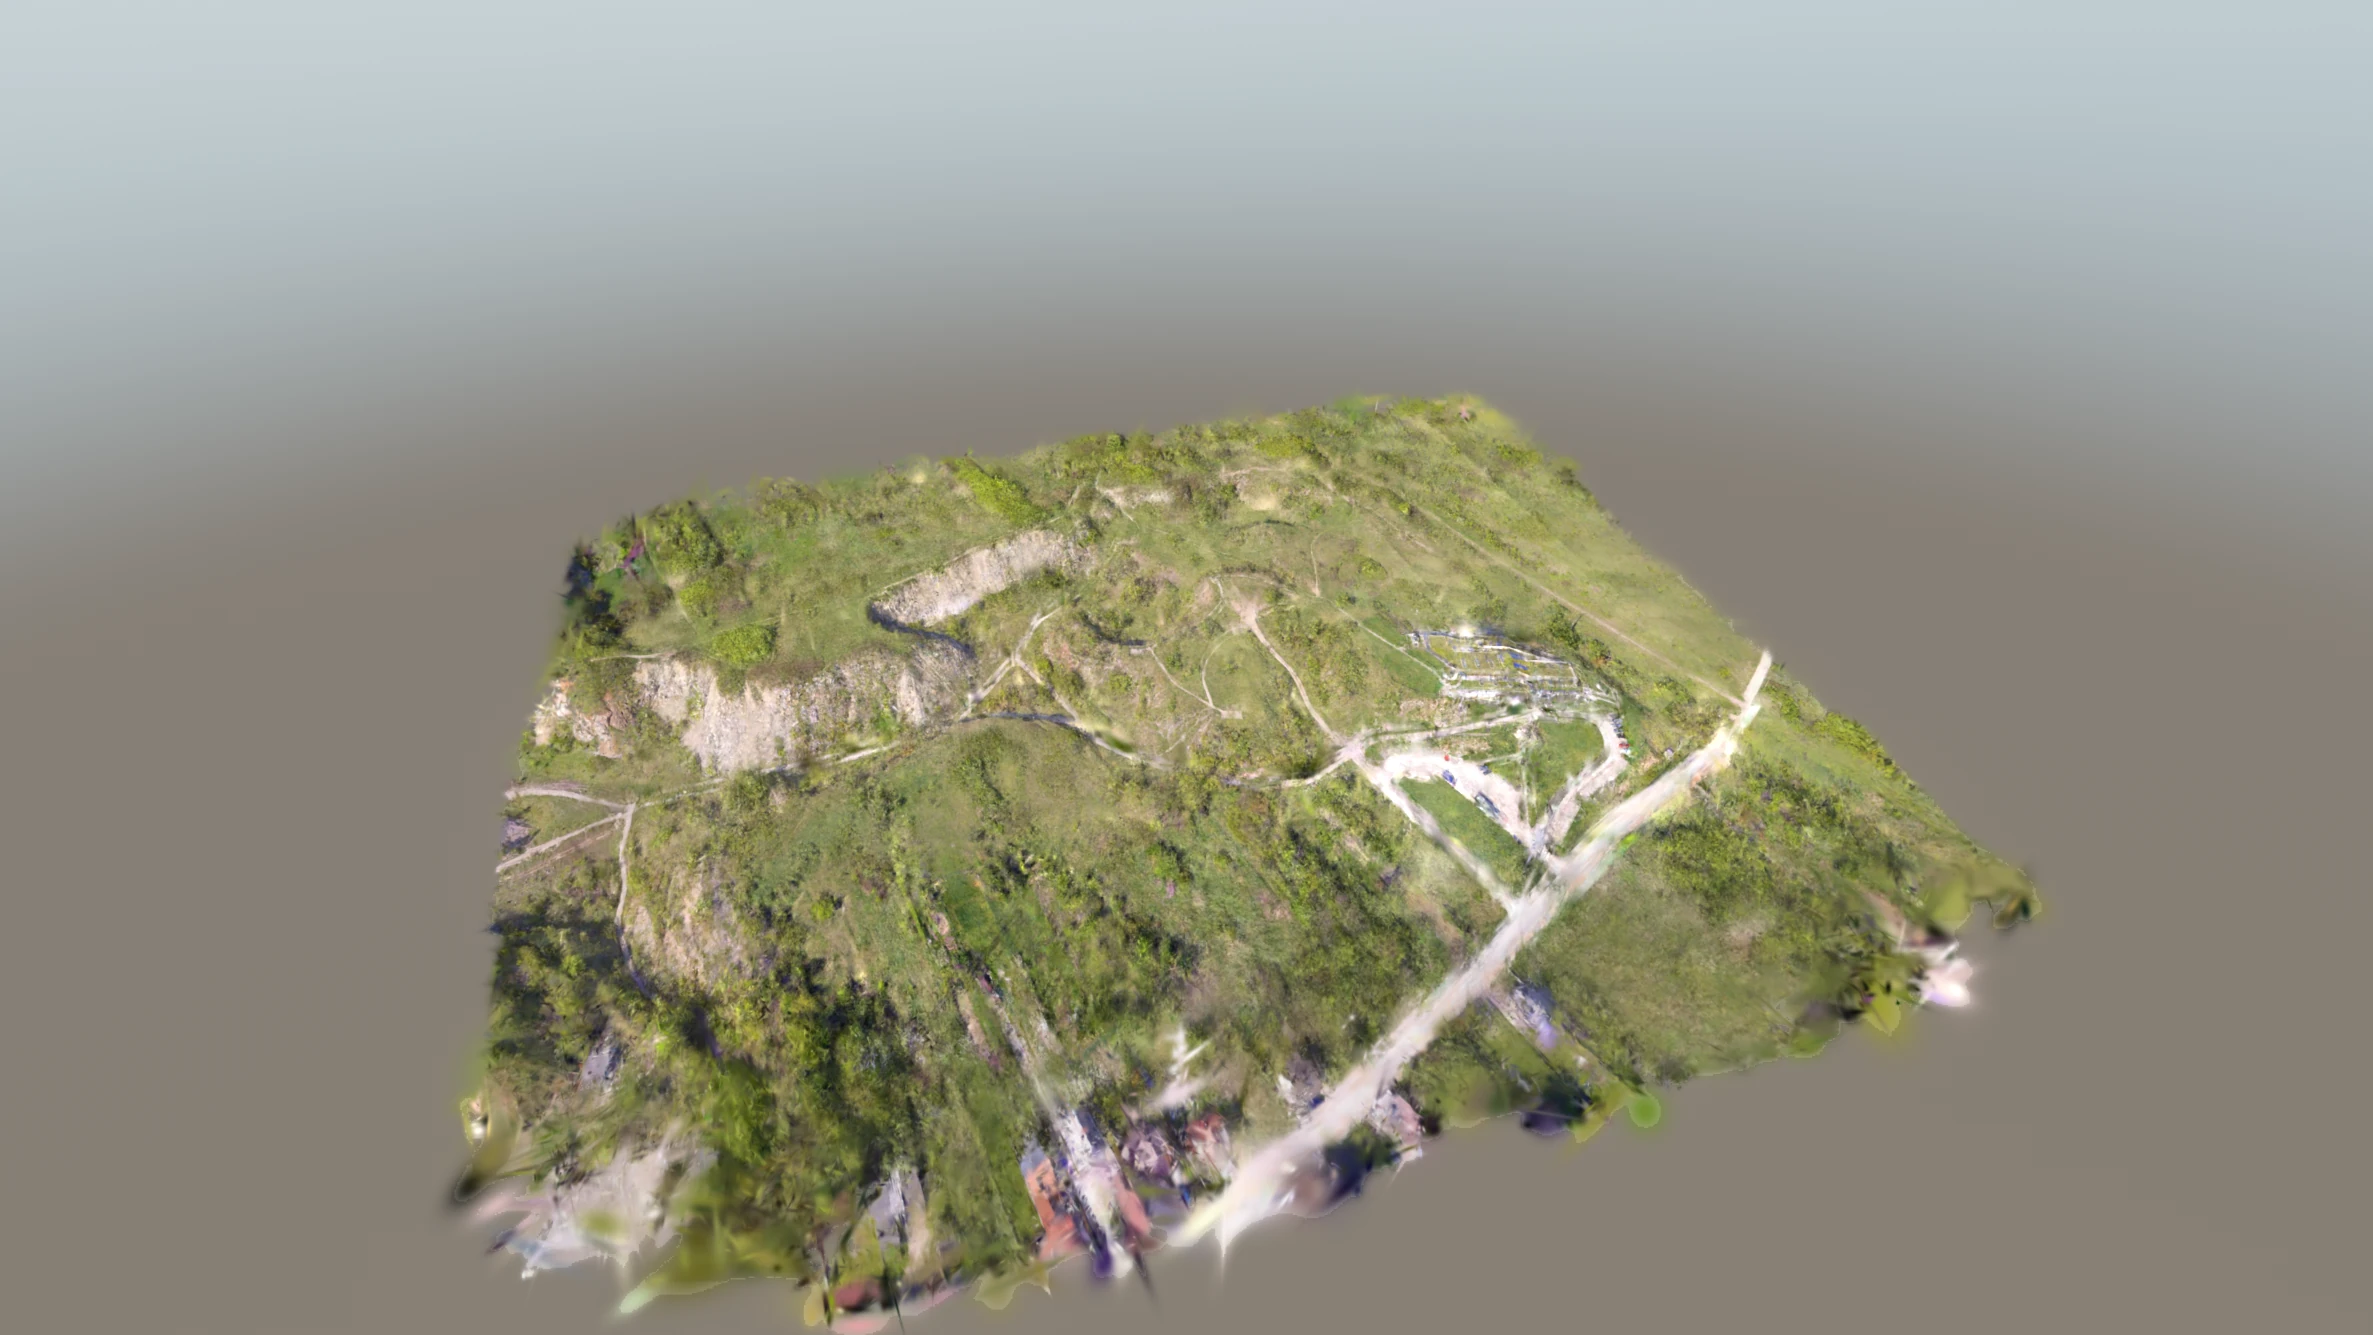
The twinmorning to nightthe application's own sky
The same place,in any light.
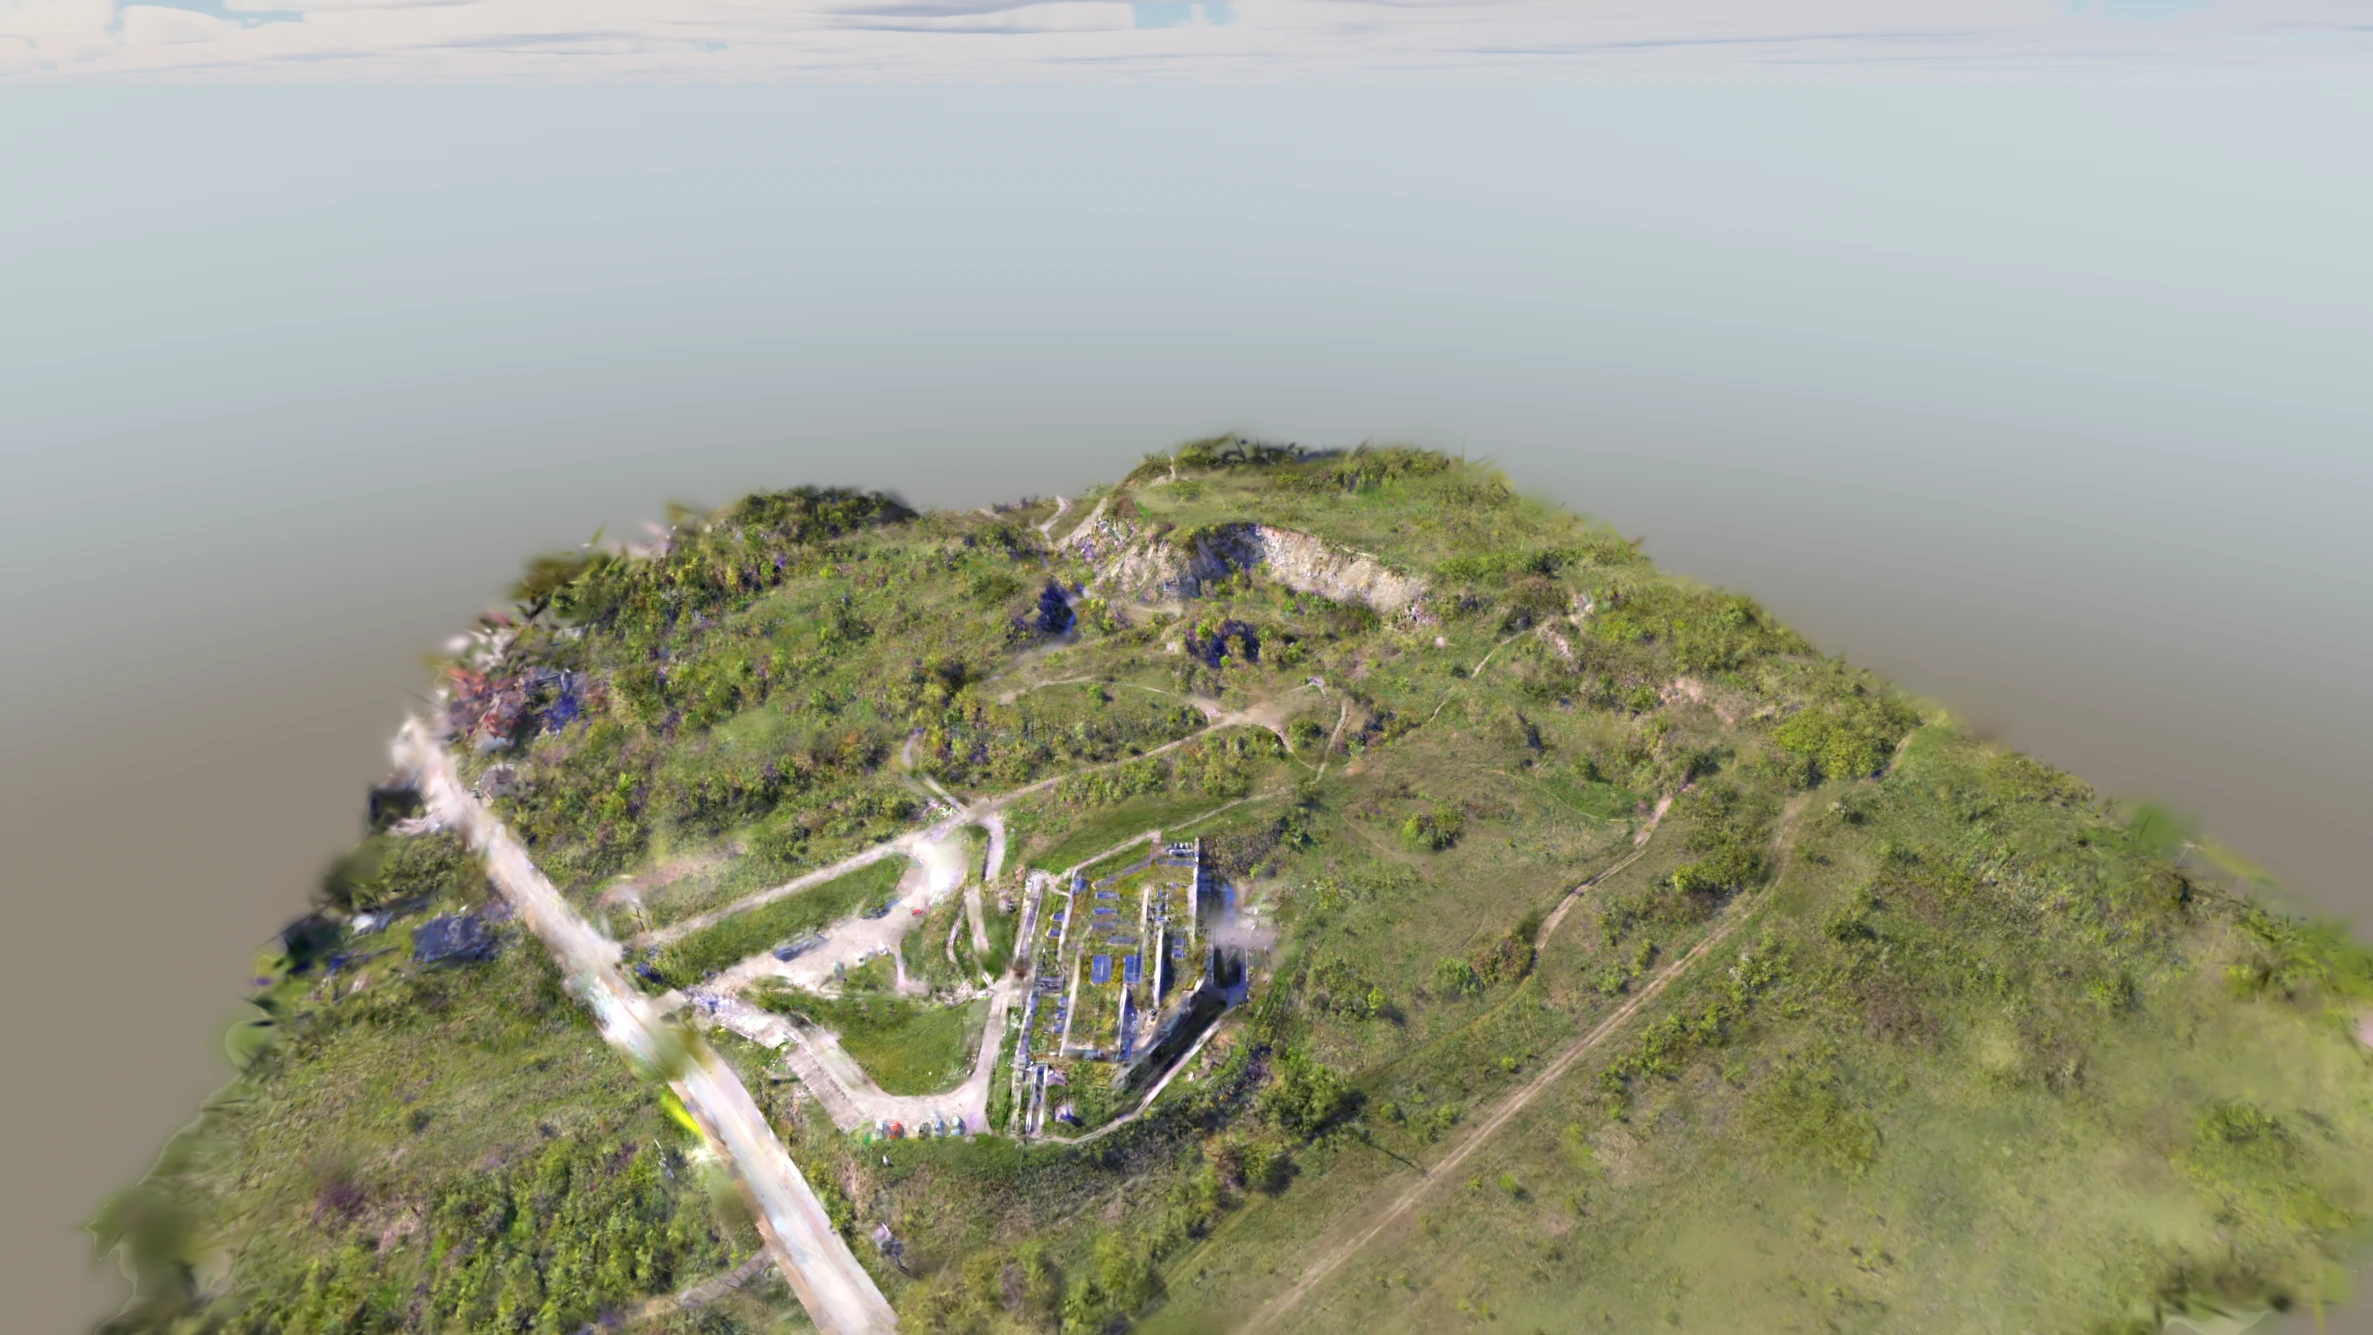
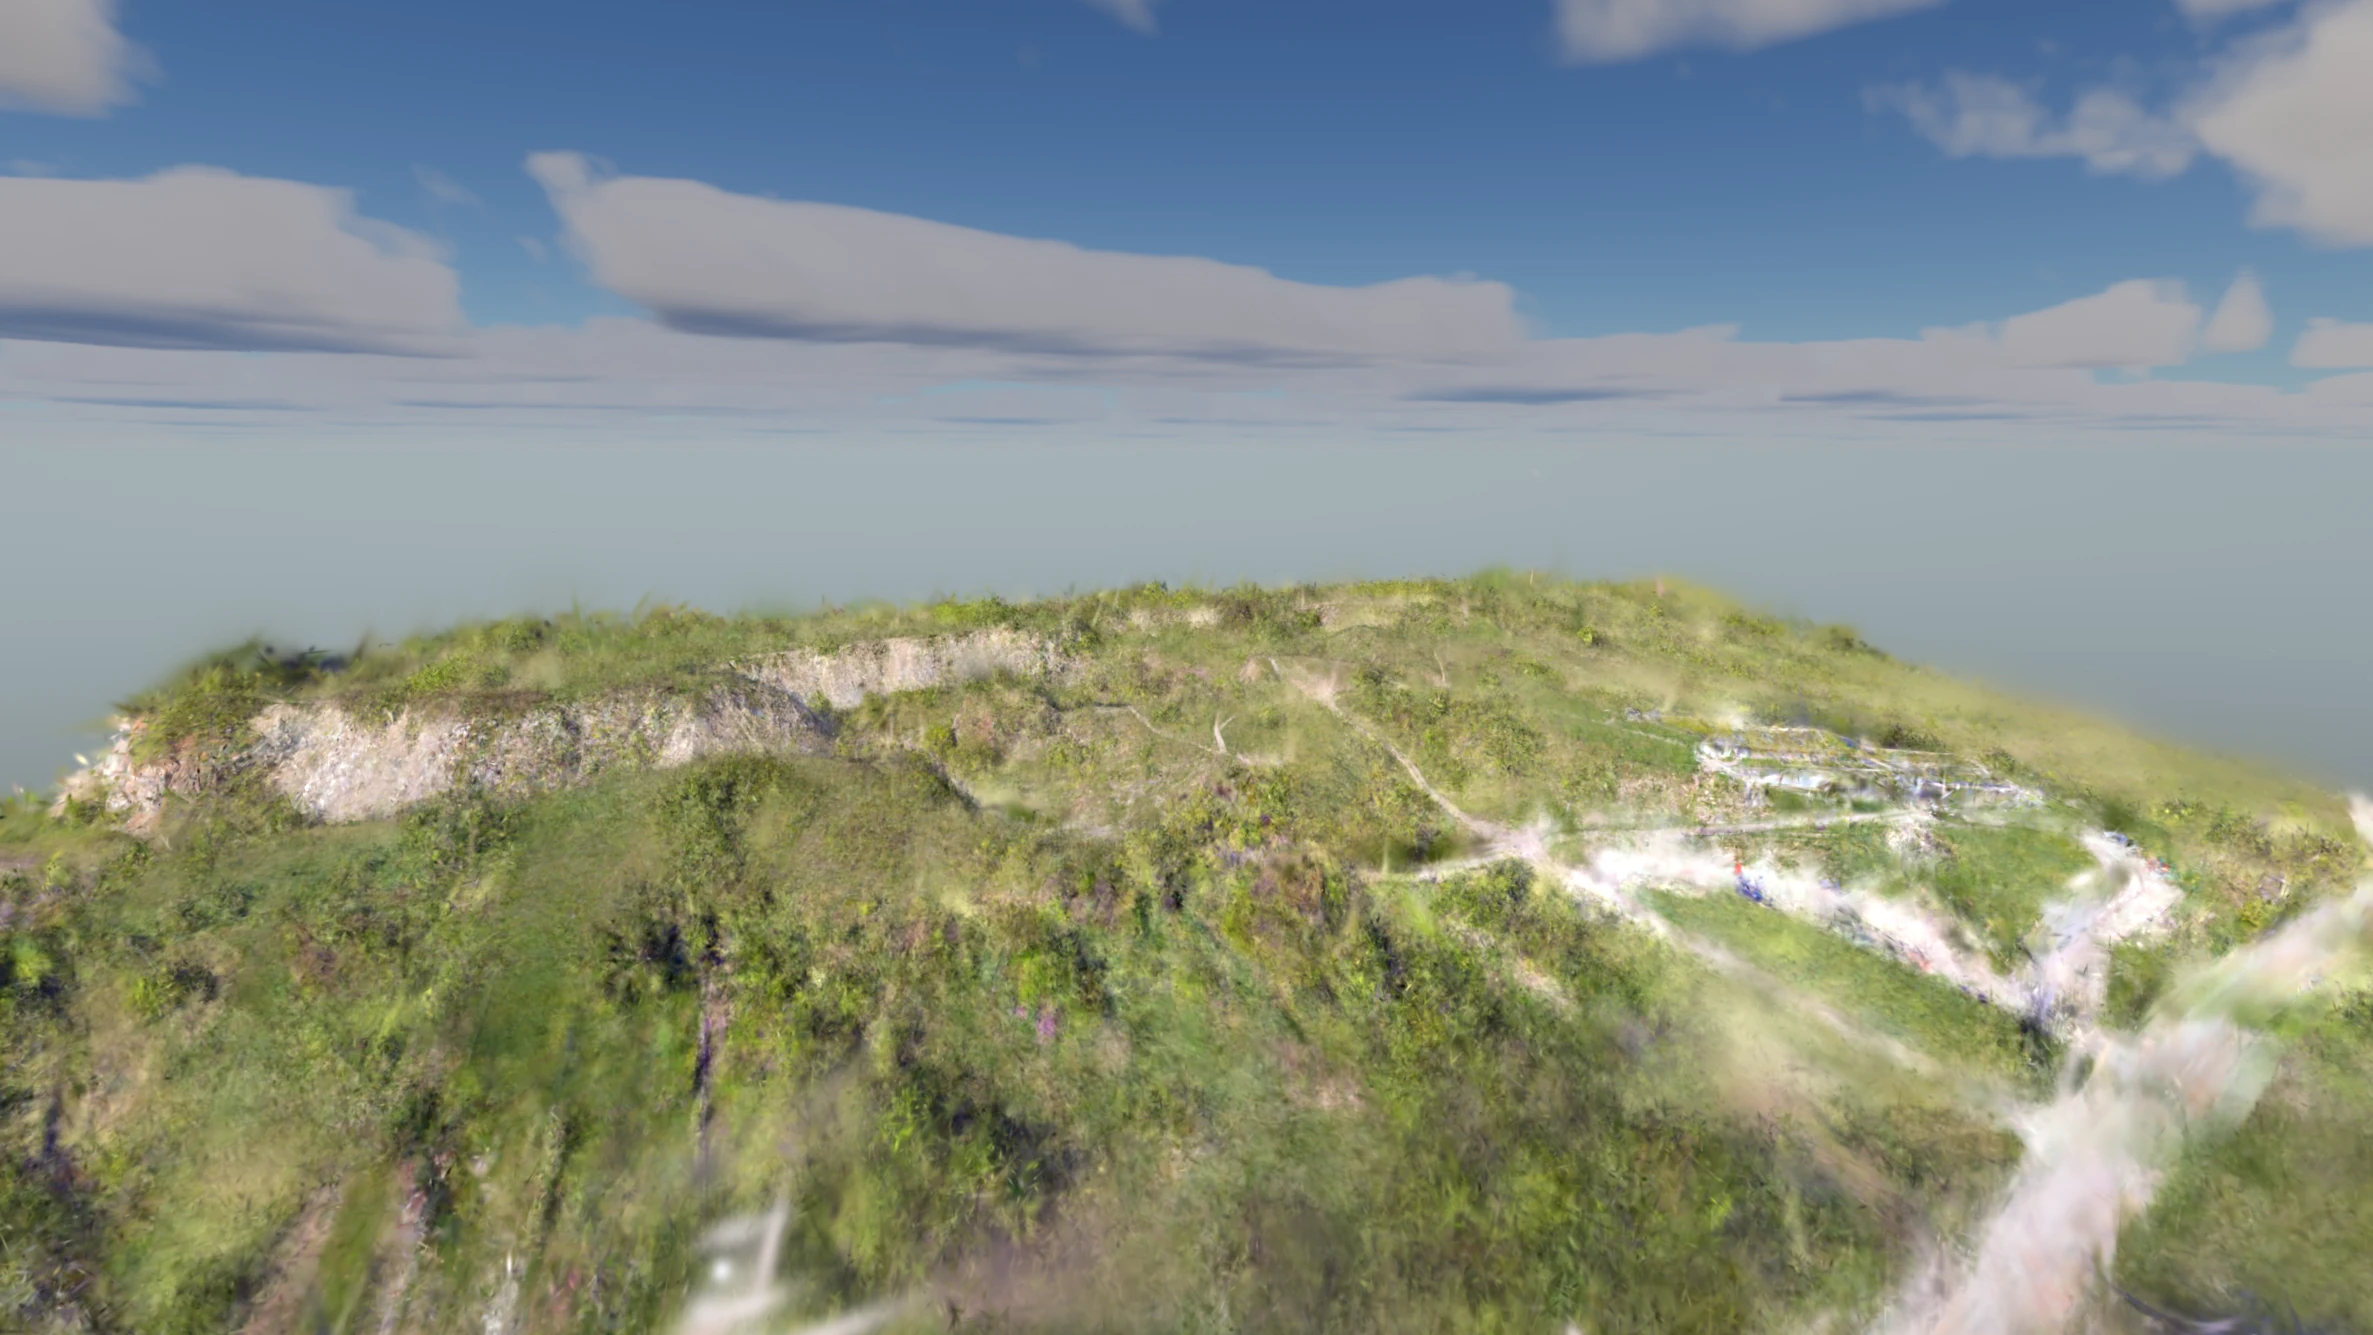
The night in the film is graded afterwards, as its label says: splats carry the light they were photographed in.
workspace.cleanClean updrag the line
What the photographscould not agree on.
Seen from outside the flown area, fresh splats smear into needles and haze. Clean up finds them from the capture's own statistics and shows what would go before anything does.
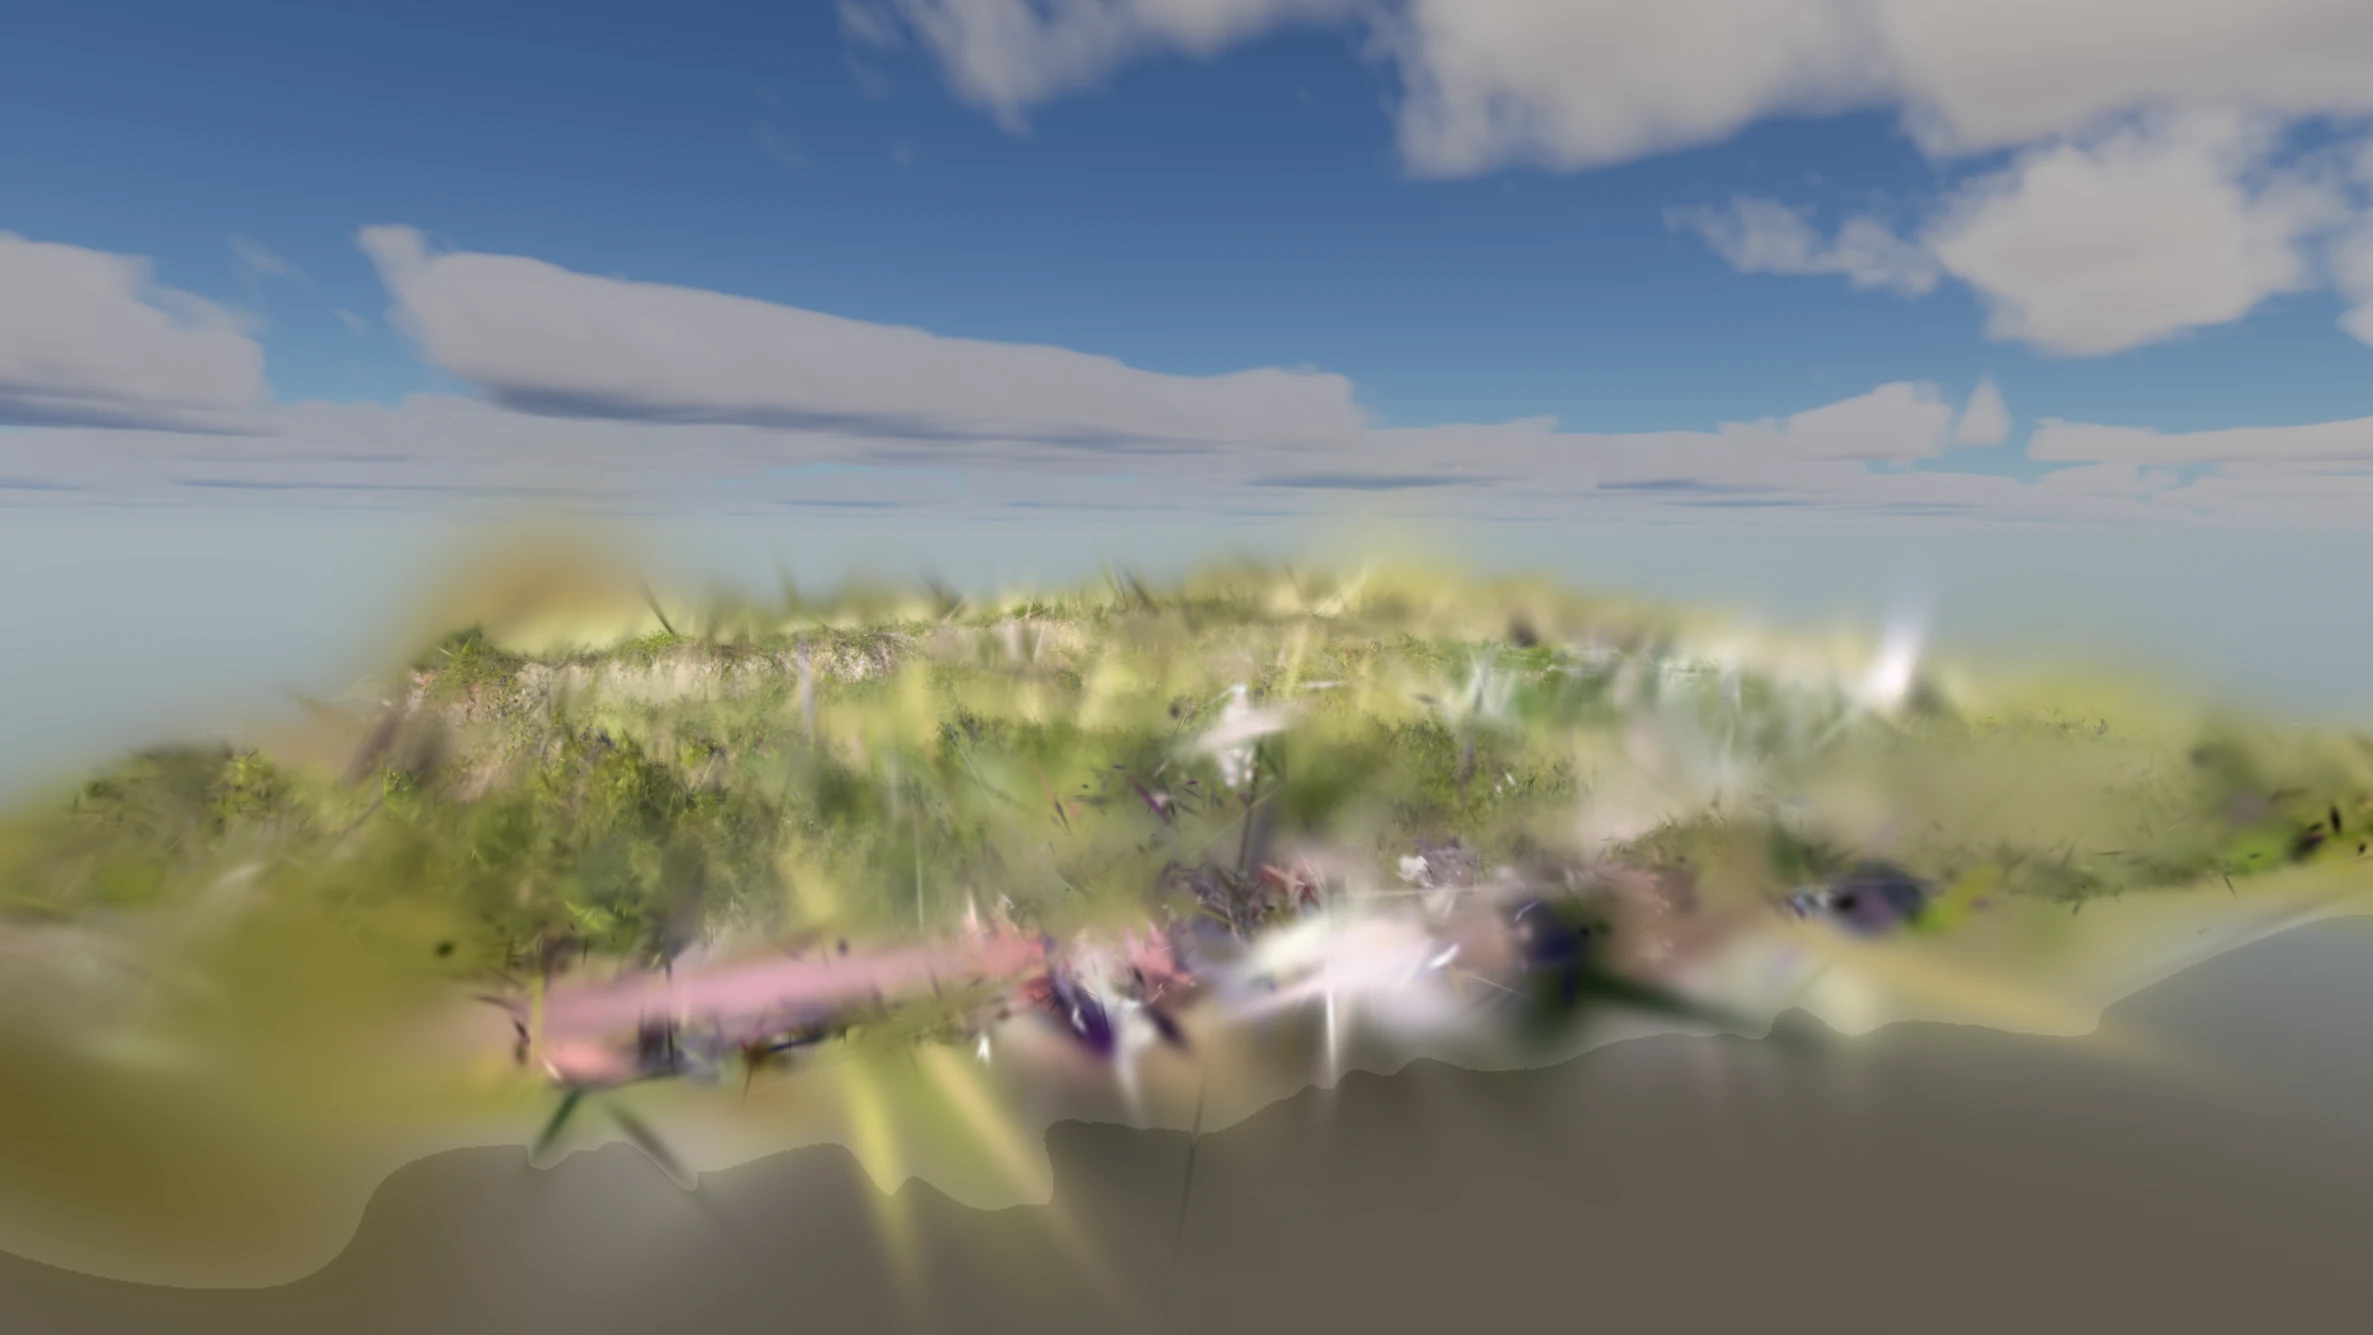
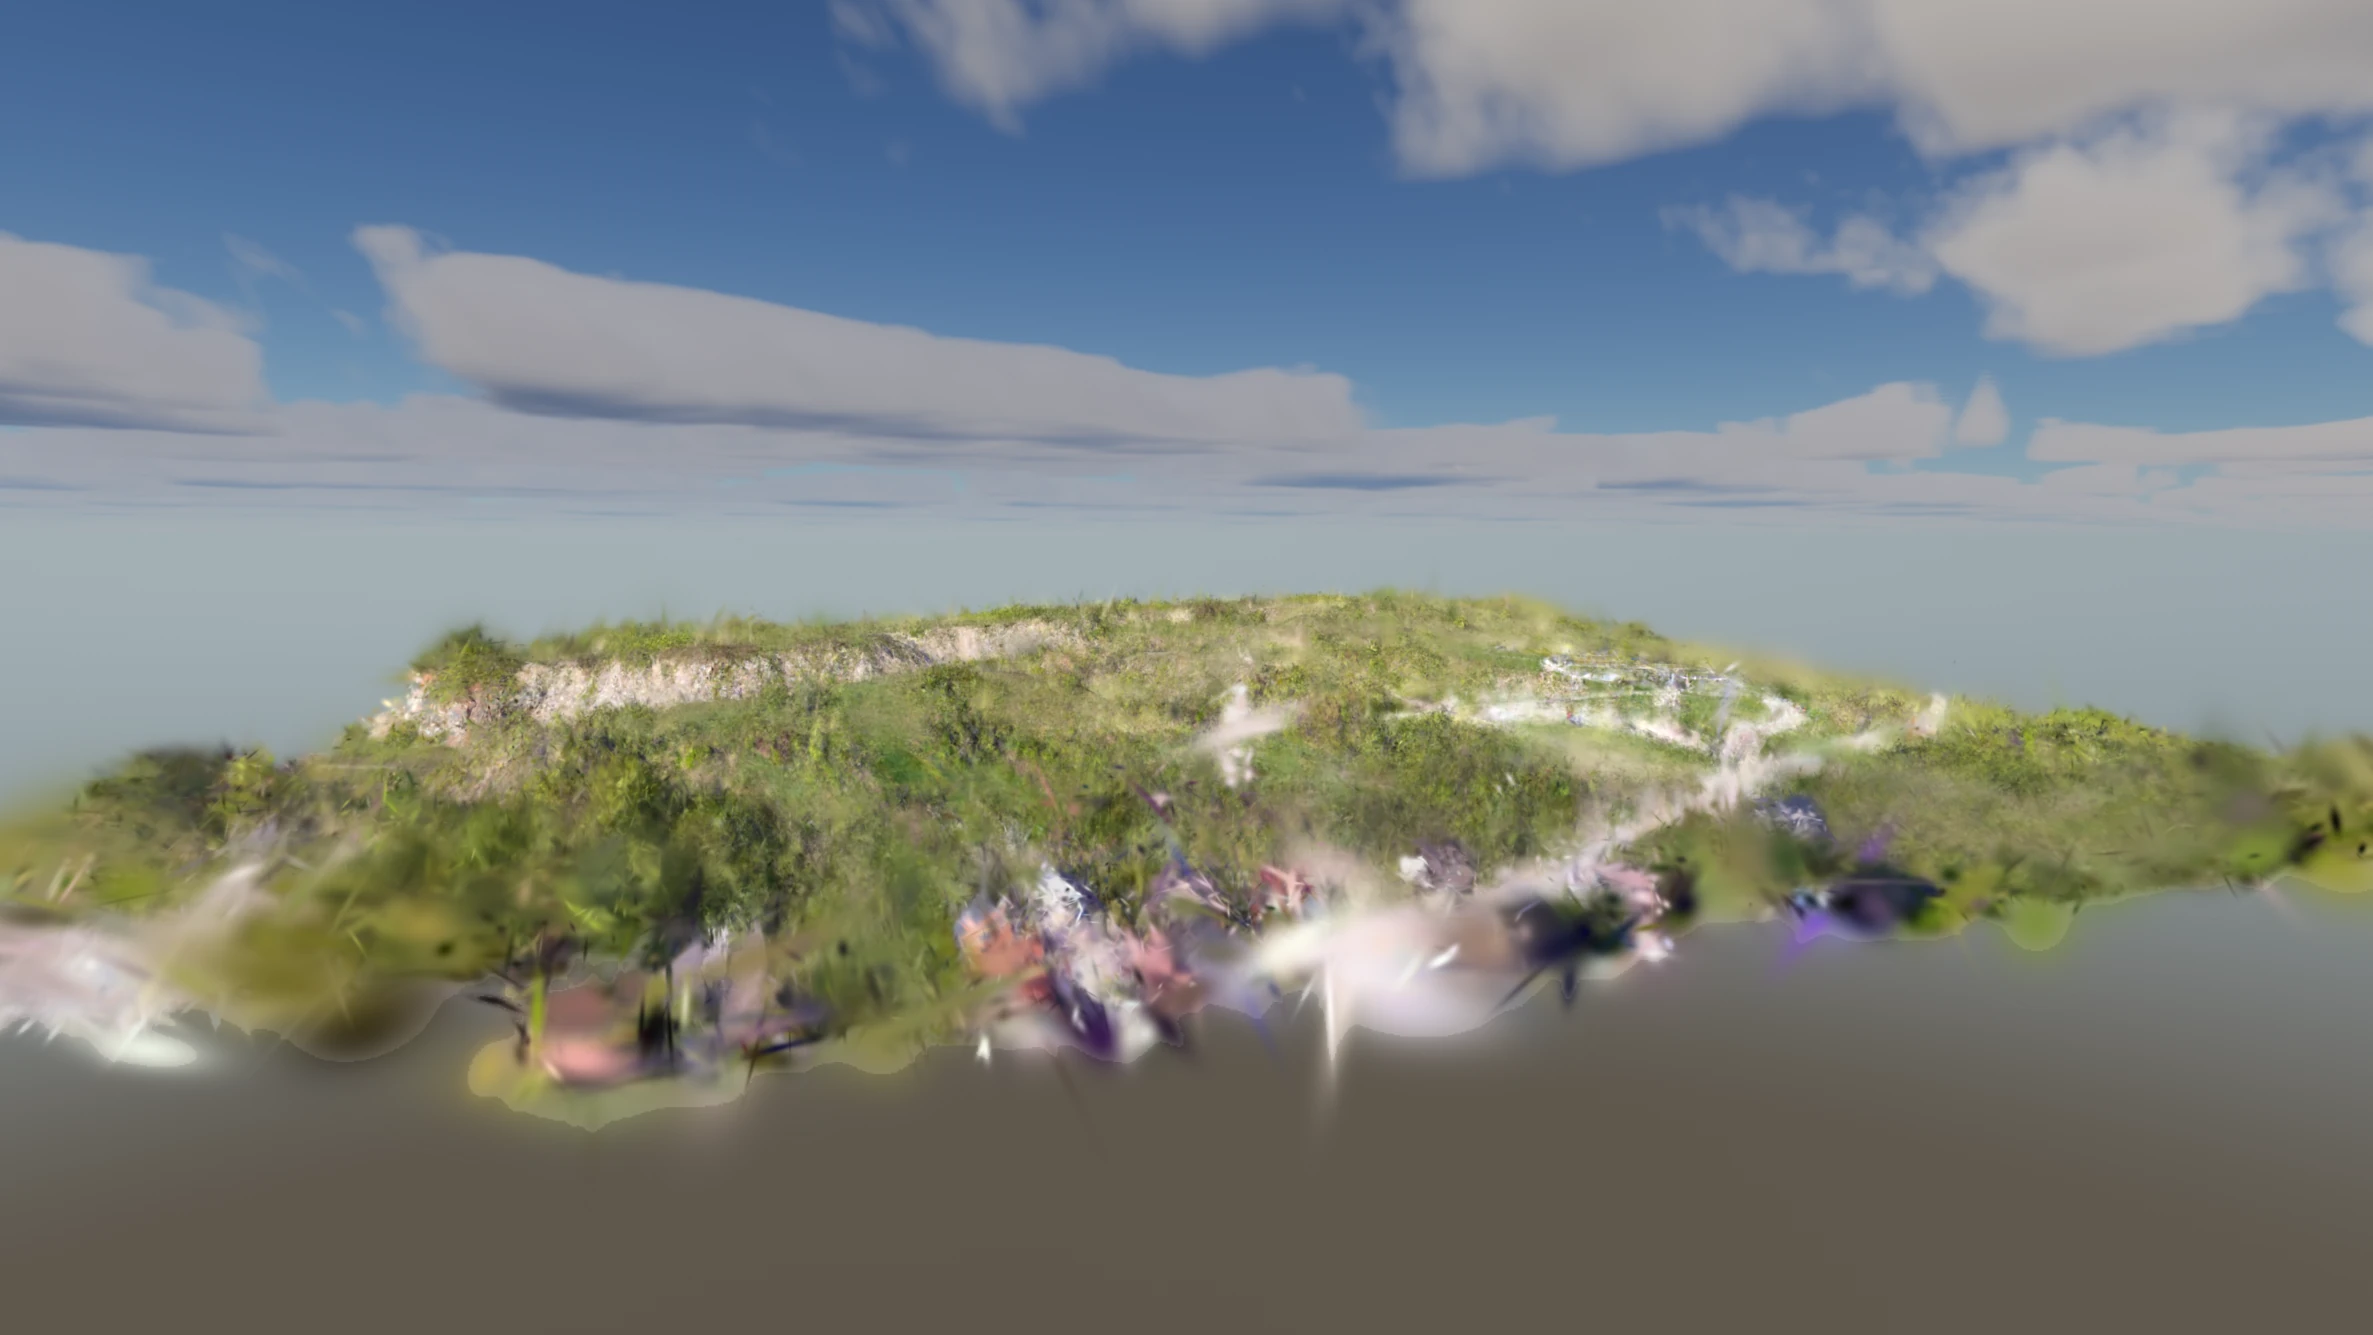 Out of trainingAfter Clean up
Clean up › Floaters · the same camera on both sides of the line
In and outformats
A folder in.Every format out.
What it does not do yet
Textured meshes still take a while to make, and making them quicker is work in progress. On AMD cards the camera solve extracts features on the CPU, which is slower. The camera-solve engine is a 1 GB download on first use. Scans are registered with a stated error; GNSS ties and targets are not supported yet.
Capture is in everypaid edition.
From €590 a year, €69 a month, or €1,390 perpetual with a year of updates. Per seat, excluding VAT. Draft prices.